University of California, Riverside

Motion Planning Lab

Understanding motion.
Building intelligent worlds.

Research in robotics, computer graphics, and AI — from navigating human crowds to learning lifelike movement.

  • Robot NavigationPhysics-Based Character Control
  • Motion SynthesisCrowd SimulationPath Planning
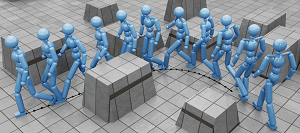
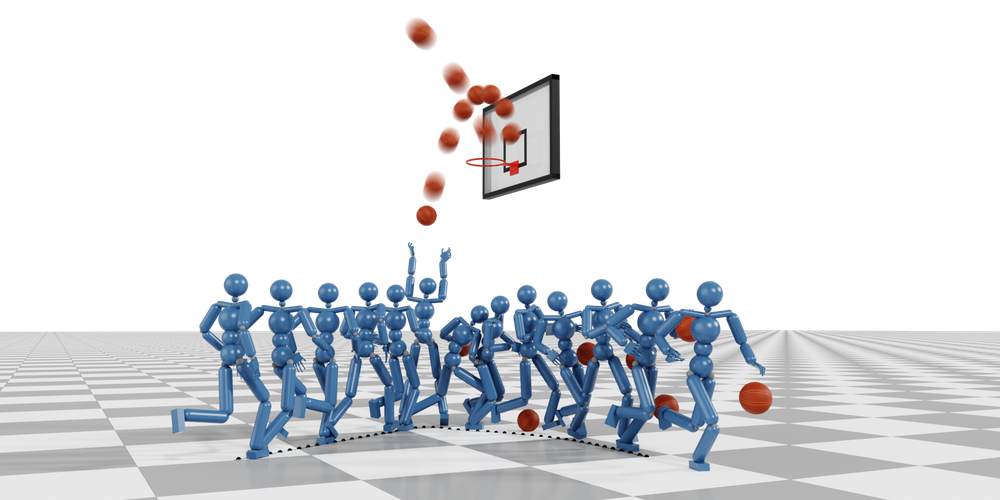
Physics-based basketball character control
Learning to move
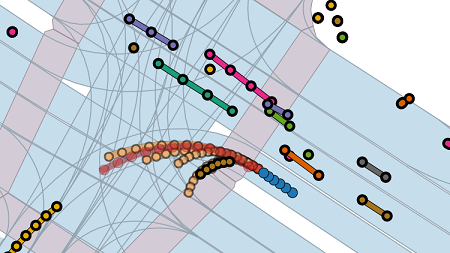
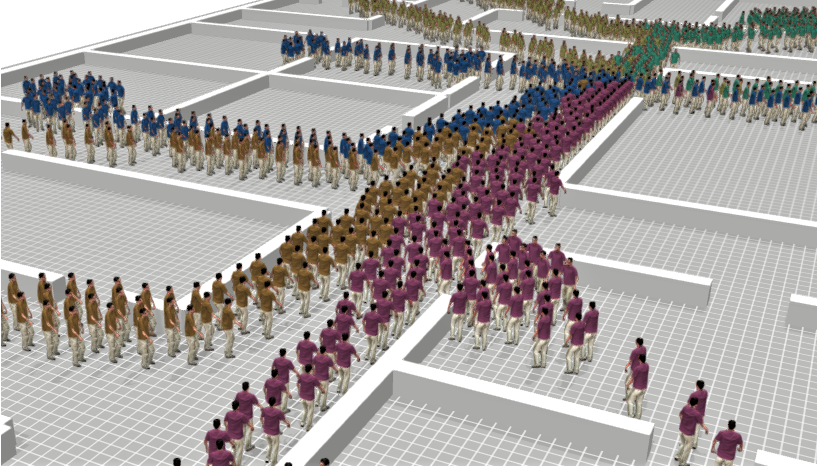
Simulated crowd navigation
Navigating together
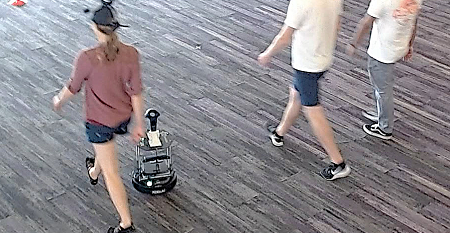
Human interactions with a service robot
Robots among people

Recent Projects

More from the lab

Learning to Ball: Composing Policies for Long-Horizon Basketball Moves

Learning to Ball: Composing Policies for Long-Horizon Basketball Moves

Pei Xu, Zhen Wu, Ruocheng Wang, Vishnu Sarukkai, Kayvon Fatahalian, Ioannis Karamouzas, Victor Zordan, and C. Karen Liu
ACM Transactions on Graphics, (SIGGRAPH Asia), 2025.
[pdf] [code]
A Study in Zucker: Insights on Interactions Between Humans and Small Service Robots

A Study in Zucker: Insights on Interactions Between Humans and Small Service Robots

Alex Day Xu and Ioannis Karamouzas
IEEE Robotics and Automation Letters 9(3), 2024.
Also in IEEE ICRA@40 , 2024.
[pdf] [project]
AdaptNet: Policy Adaptation for Physics-Based Character Control

AdaptNet: Policy Adaptation for Physics-Based Character Control

Pei Xu, Kaixiang Xie, Sheldon Andrews, Paul G. Kry, Michael Neff, Morgan McGuire, Ioannis Karamouzas, and Victor Zordan
ACM Transactions on Graphics, 42(6),(SIGGRAPH Asia), 2024.
[pdf] [project] [code]
Context-Aware Timewise VAEs for Real-Time Vehicle Trajectory Prediction

Context-Aware Timewise VAEs for Real-Time Vehicle Trajectory Prediction

Pei Xu, Jean-Bernard Hayet, and Ioannis Karamouzas
IEEE Robotics and Automation Letters, 8(9), 2023.
Also in IEEE International Conference on Robotics and Automation , 2024.
[pdf] [project] [code]
Composite Motion Learning with Task Control

Composite Motion Learning with Task Control

Pei Xu, Xiumin Shang, Victor Zordan, and Ioannis Karamouzas
ACM Transactions on Graphics, 42(4),(SIGGRAPH), 2023.
[pdf] [project] [code]
SocialVAE: Human Trajectory Prediction using Timewise Latents

SocialVAE: Human Trajectory Prediction using Timewise Latents

Pei Xu, Jean-Bernard Hayet, and Ioannis Karamouzas
In the 17th European Conference on Computer Vision (ECCV 2022), 2022.
[pdf] [project] [code]
Human-Inspired Multi-Agent Navigation using Knowledge Distillation

Human-Inspired Multi-Agent Navigation using Knowledge Distillation

Pei Xu and Ioannis Karamouzas
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2021), 2021.
[pdf] [project] [code]
NH-TTC: A gradient-based framework for generalized anticipatory collision avoidance

NH-TTC: A gradient-based framework for generalized anticipatory collision avoidance

Bobby Davis, Ioannis Karamouzas, and Stephen J. Guy,
In Robotics: Science and Systems (RSS 2020), 2020.
[pdf] [project] [code]

Prospective Students

We welcome motivated students who are excited about robotics, computer graphics, and embodied AI. If you are interested in joining the Motion Planning Lab 🤖 as a Ph.D. student, consider applying to the UCR's Ph.D. program in CS and mention Prof. Ioannis Karamouzas as a potential advisor.

If you would like to reach out, please read David Evans' advice on contacting professors about graduate school. Please write two brief paragraphs in your own words: one explaining why you want to pursue a PhD and how your interests connect to our lab, and one describing your current work or research experience. Do not send AI-generated emails.


Sponsors

We would like to thank Amazon, the National Science Foundation, Roblox, and University of California, Riverside for supporting our research.

Web Analytics